Jungil Ham
Ph.D. Candidate in Mechanical and Robotics Engineering

Gwangju, South Korea 61005
I develop robust visual localization and SLAM for robots, from complex environments on Earth to the International Space Station.

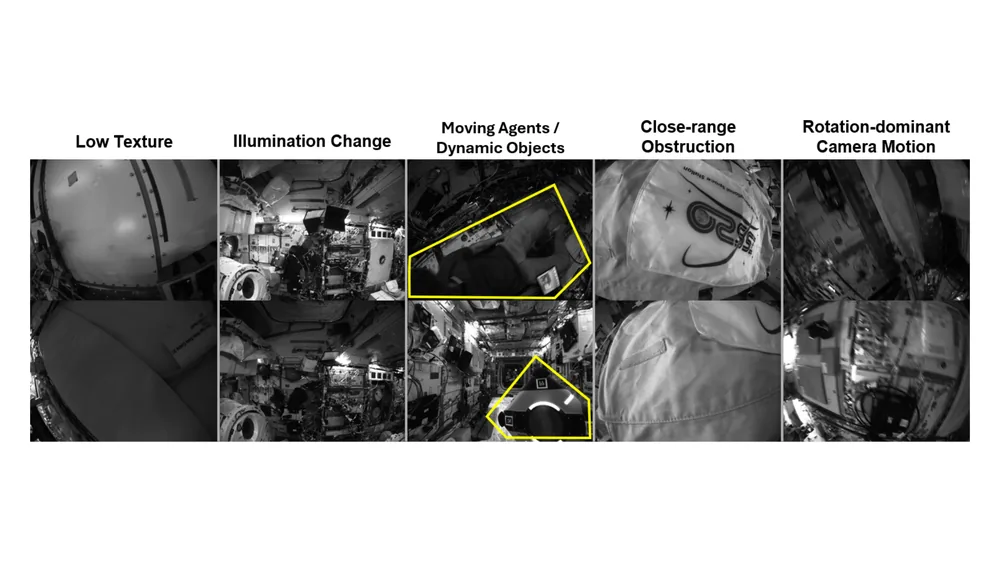
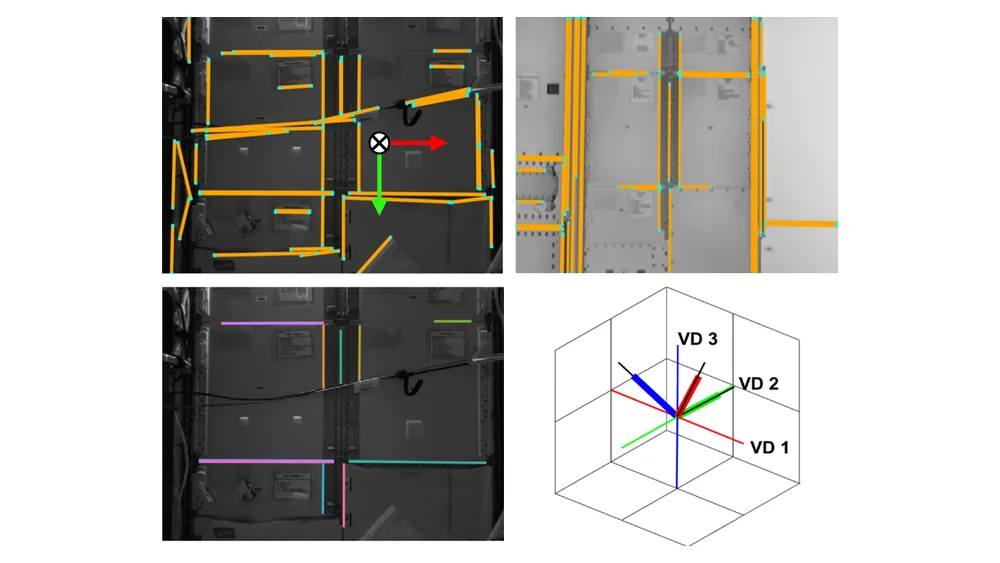
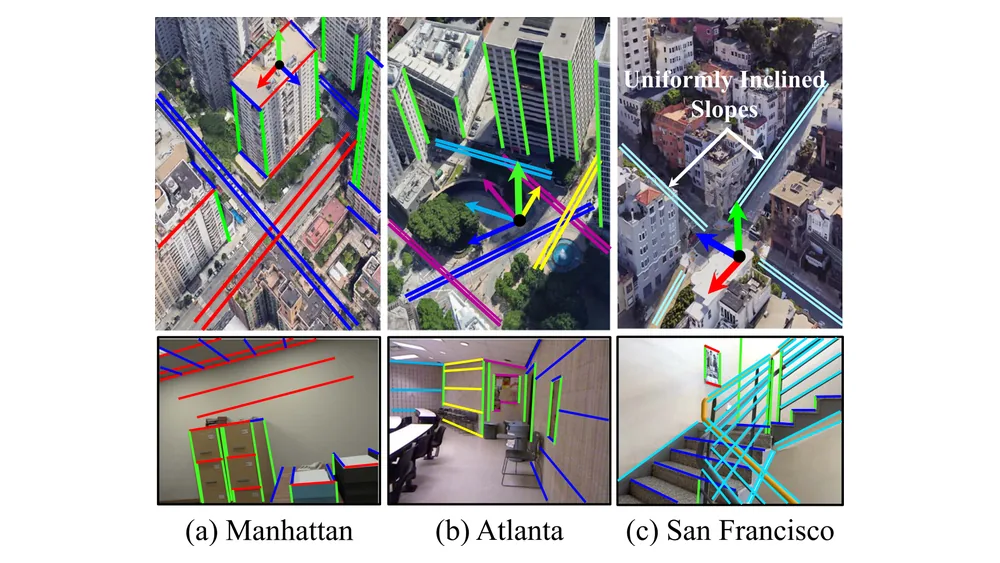
I’m a Ph.D. candidate in the Machine Perception and Intelligence Lab (MPIL) at GIST, advised by Pyojin Kim. I build structure-aware visual localization: San Francisco World (RA-L 2025), SF-SLAM (IEEE T-RO, under review), DTOR, an ISS digital-twin compass, and a microgravity SLAM benchmark on NASA’s Astrobee (ICRA 2026 workshop). Currently working on digital-twin SLAM for Astrobee and dynamic Gaussian Splatting SLAM.
Previously: research intern at the NASA Ames Intelligent Robotics Group. M.S., GIST · B.S., Kwangwoon University. Full details in my CV.
Selected Publications
2026
-
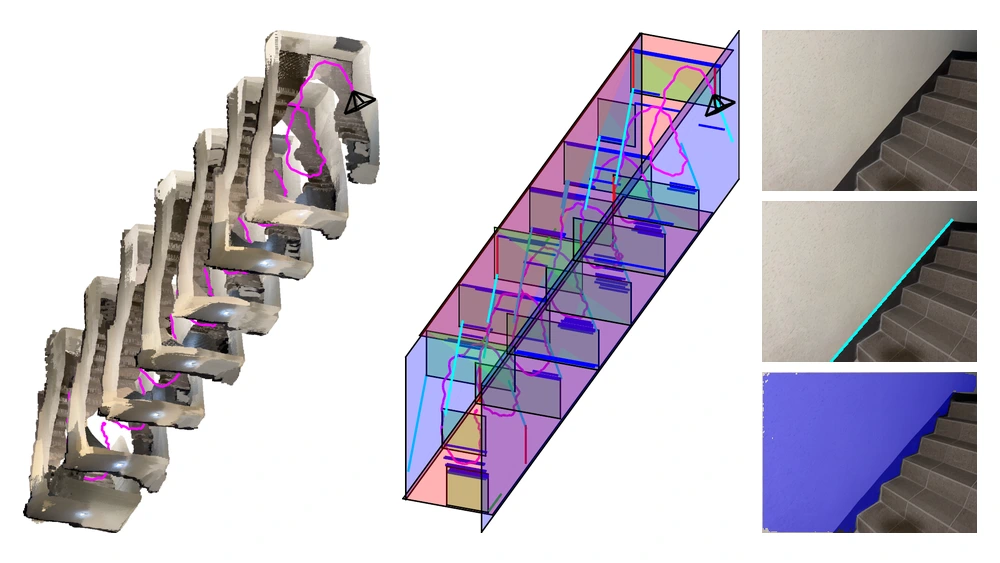 San Francisco SLAM: Structural Localization and Mapping Beyond the Manhattan WorldIEEE Transactions on Robotics (T-RO), under review, 2026* Equal contribution
2025
News
| Jun 1, 2026 | I presented our Astrobee microgravity SLAM benchmark at the ICRA 2026 Space Robotics Workshop |
|---|---|
| Jul 29, 2025 | I presented DTOR at the 2nd Space Robotics Workshop, IEEE Space Computing Conference |
| May 20, 2025 | I presented San Francisco World at ICRA 2025 |
| Apr 1, 2025 | I was selected as a Yuilhan Scholar by the Yuhan Foundation |
| Oct 1, 2024 | I received the GIST International Research Experience Fellowship, which funded the internship at NASA Ames |
| Aug 9, 2024 | I was selected for a research internship at the NASA Ames Intelligent Robotics Group |