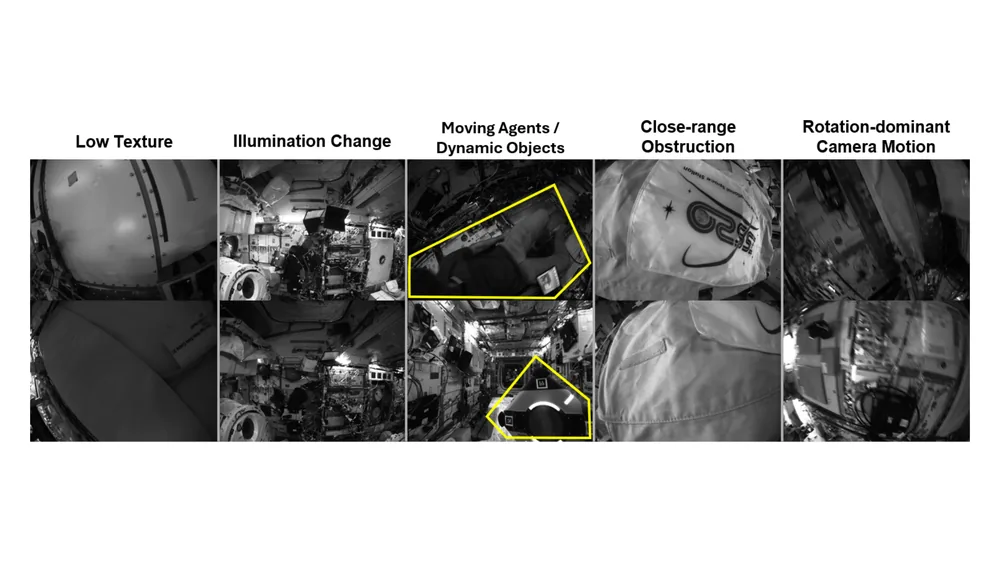
@inproceedings{ham2026microgravity,title={What Breaks Monocular SLAM in Microgravity? An Initial Benchmark on Rotation-Dominant Astrobee ISS Sequences},author={Ham, Jungil and Coltin, Brian and Soussan, Ryan and Kim, Pyojin},booktitle={IEEE International Conference on Robotics and Automation (ICRA) Space Robotics Workshop (SRW)},year={2026},organization={IEEE},video={https://youtu.be/YvrE_u011QY},}
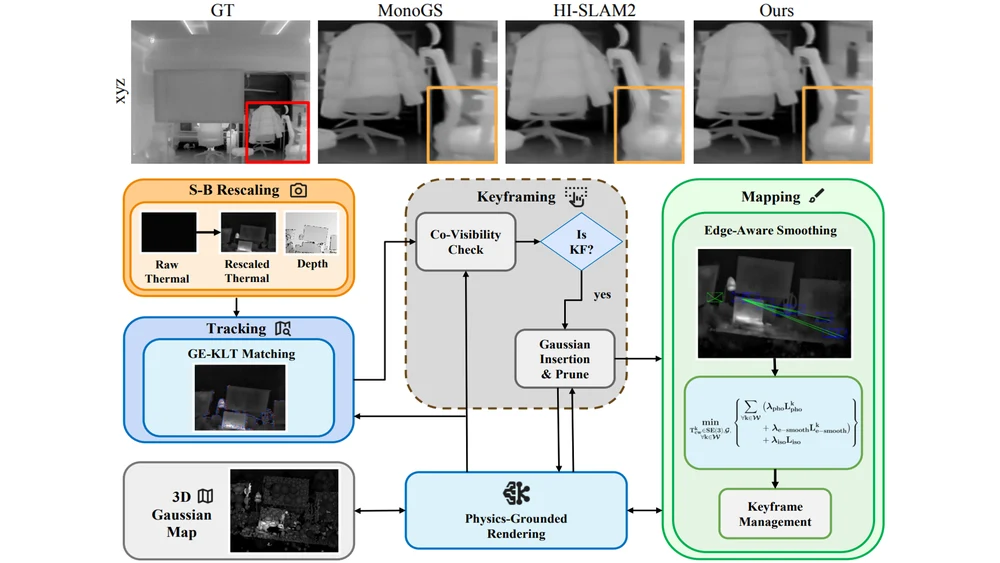
PI-EAT-SLAM: Physics-Informed Edge-Aware Thermal Gaussian Splatting SLAM
Junpyo Kim, Seonwook Yeom, Seonmo Yang, Jungil Ham, Hyeonji Shin, Changhyeon Kim, Hyeonbeom Lee, and Pyojin Kim
In IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026
@inproceedings{kim2026pieat,title={PI-EAT-SLAM: Physics-Informed Edge-Aware Thermal Gaussian Splatting SLAM},author={Kim, Junpyo and Yeom, Seonwook and Yang, Seonmo and Ham, Jungil and Shin, Hyeonji and Kim, Changhyeon and Lee, Hyeonbeom and Kim, Pyojin},booktitle={IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},year={2026},organization={IEEE},}
2025
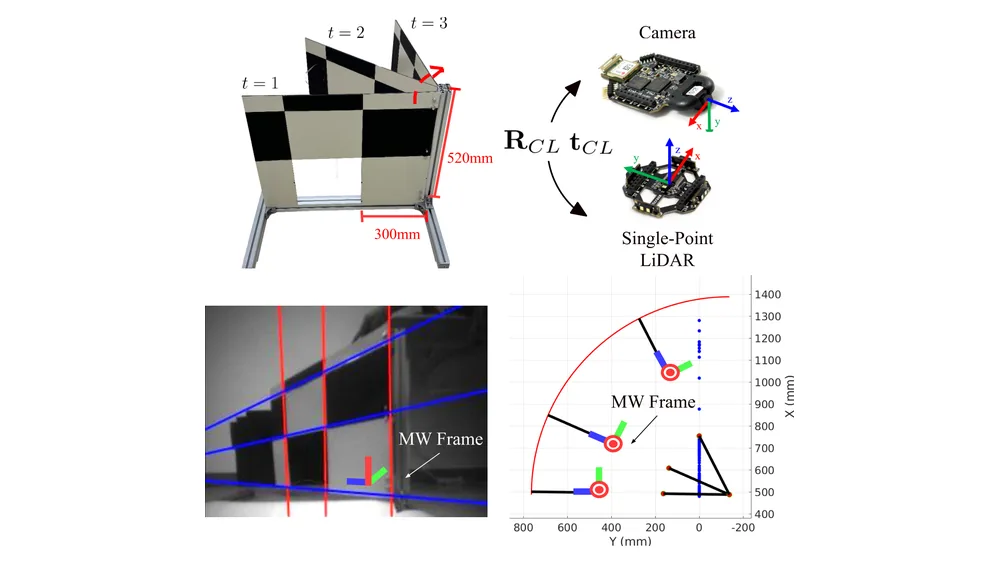
SPLiCE: Single-Point LiDAR and Camera Calibration & Estimation Leveraging Manhattan World
@inproceedings{kim2025splice,title={SPLiCE: Single-Point LiDAR and Camera Calibration \& Estimation Leveraging Manhattan World},author={Kim, Minji and Han, Jeahn and Ham, Jungil and Kim, Pyojin},booktitle={IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS)},pages={8727--8734},year={2025},organization={IEEE},doi={10.1109/IROS60139.2025.11247164},}
Drift-Free Visual Compass Leveraging Digital Twins for Cluttered Environments
@inproceedings{ham2025dtor,title={Drift-Free Visual Compass Leveraging Digital Twins for Cluttered Environments},author={Ham, Jungil and Soussan, Ryan and Coltin, Brian and Chun, Hoyeong and Kim, Pyojin},booktitle={2nd Space Robotics Workshop (SRW) at IEEE Space Computing Conference (SCC)},address={Pasadena, CA, USA},year={2025},organization={IEEE},}
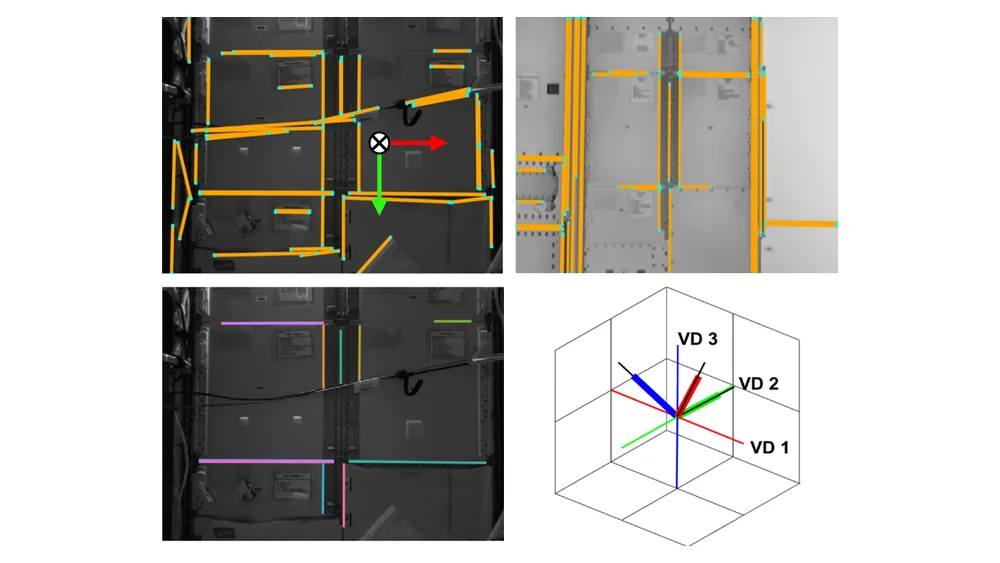
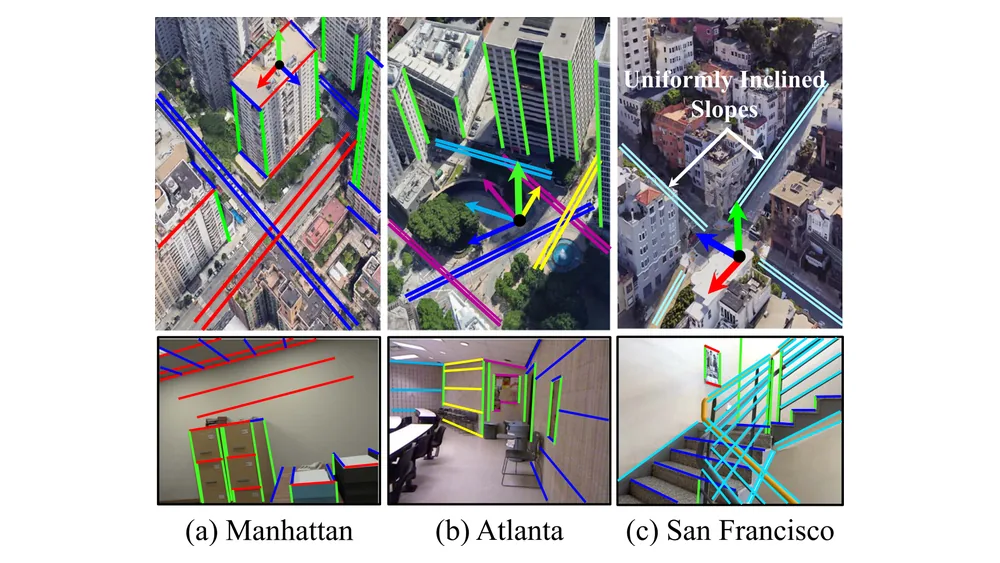
San Francisco World: Leveraging Structural Regularities of Slope for 3-DoF Visual Compass
Jungil Ham, Minji Kim, Suyoung Kang, Kyungdon Joo, Haoang Li, and Pyojin Kim
@article{ham2025san,title={San Francisco World: Leveraging Structural Regularities of Slope for 3-DoF Visual Compass},author={Ham, Jungil and Kim, Minji and Kang, Suyoung and Joo, Kyungdon and Li, Haoang and Kim, Pyojin},journal={IEEE Robotics and Automation Letters},volume={10},number={1},pages={382--389},year={2025},publisher={IEEE},doi={10.1109/LRA.2024.3504315},}
2023
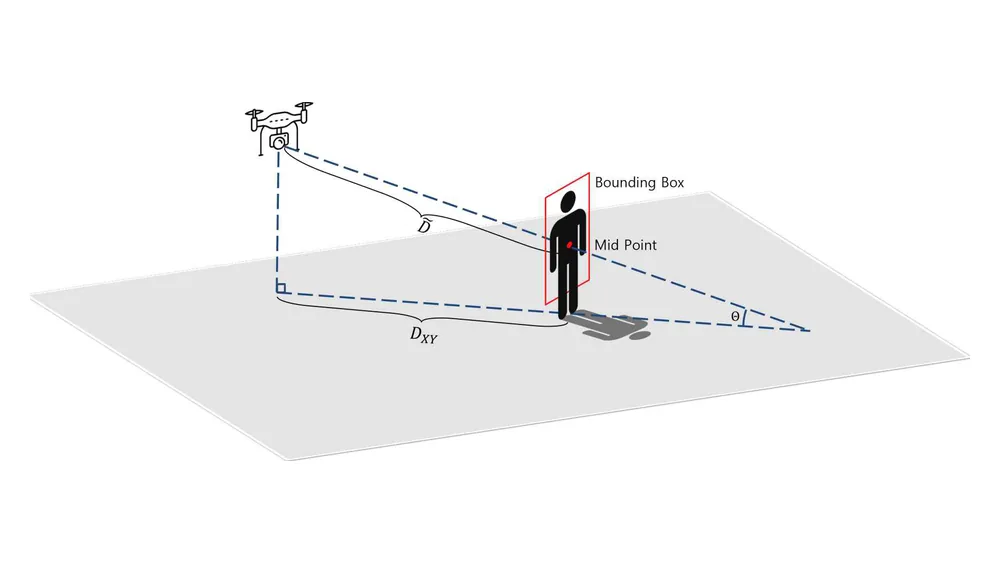
Indoor Pedestrian-Following System by a Drone with Edge Computing and Neural Networks: Part 2-Development of Tracking System and Monocular Depth Estimation
Jung-Il Ham, In-Chan Ryu, Jun-Oh Park, Jae-Woo Joeng, Sung-Chang Kim, and Hyo-Sung Ahn
In 2023 23rd International Conference on Control, Automation and Systems (ICCAS), 2023
@inproceedings{ham2023indoor,title={Indoor Pedestrian-Following System by a Drone with Edge Computing and Neural Networks: Part 2-Development of Tracking System and Monocular Depth Estimation},author={Ham, Jung-Il and Ryu, In-Chan and Park, Jun-Oh and Joeng, Jae-Woo and Kim, Sung-Chang and Ahn, Hyo-Sung},booktitle={2023 23rd International Conference on Control, Automation and Systems (ICCAS)},pages={1532--1537},year={2023},organization={IEEE},}
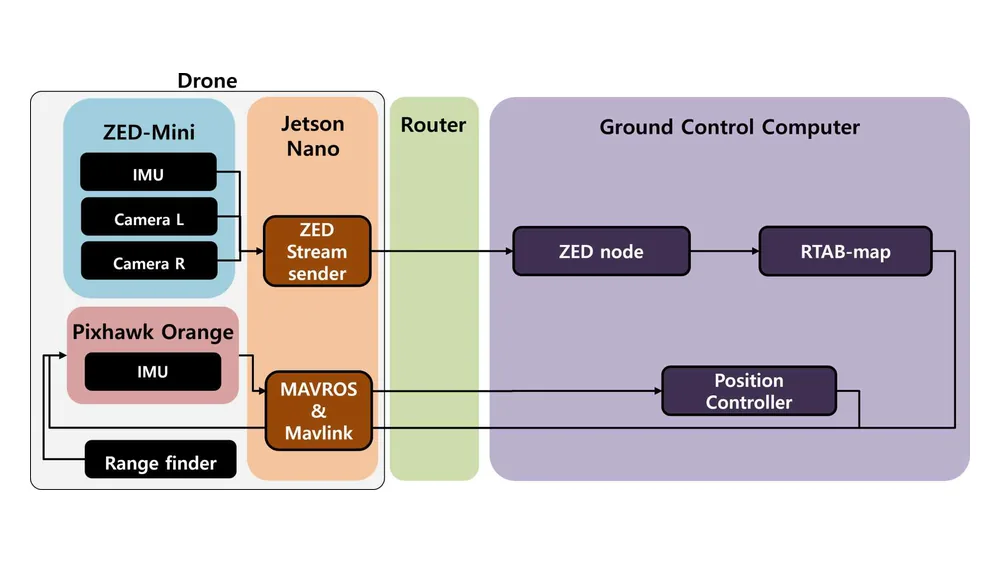
Indoor Pedestrian-Following System by a Drone with Edge Computing and Neural Networks: Part 1-System Design
In-Chan Ryu, Jung-Il Ham, Jun-Oh Park, Jae-Woo Joeng, Sung-Chang Kim, and Hyo-Sung Ahn
In 2023 23rd International Conference on Control, Automation and Systems (ICCAS), 2023
@inproceedings{ryu2023indoor,title={Indoor Pedestrian-Following System by a Drone with Edge Computing and Neural Networks: Part 1-System Design},author={Ryu, In-Chan and Ham, Jung-Il and Park, Jun-Oh and Joeng, Jae-Woo and Kim, Sung-Chang and Ahn, Hyo-Sung},booktitle={2023 23rd International Conference on Control, Automation and Systems (ICCAS)},pages={1526--1531},year={2023},organization={IEEE},}
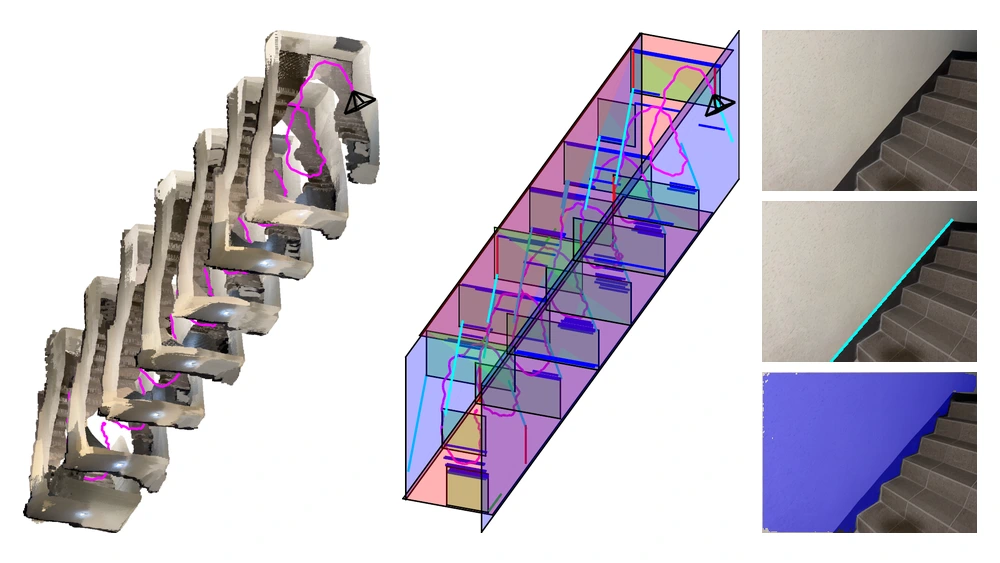 San Francisco SLAM: Structural Localization and Mapping Beyond the Manhattan WorldIEEE Transactions on Robotics (T-RO), under review, 2026* Equal contribution